Aero System

Aero Hand & Aero UMI

Co-designed for learning and execution

Aero System pairs a dexterous robotic hand with a wearable demonstration interface. Aero Hand performs the task. Aero UMI captures how a person performs it. Together, they align motion and contact from human demonstration to robotic execution.

Built for researchers and robot builders working toward precise, reliable manipulation.

Interested? Contact us →
Meet the system
Aero Hand on a robot arm

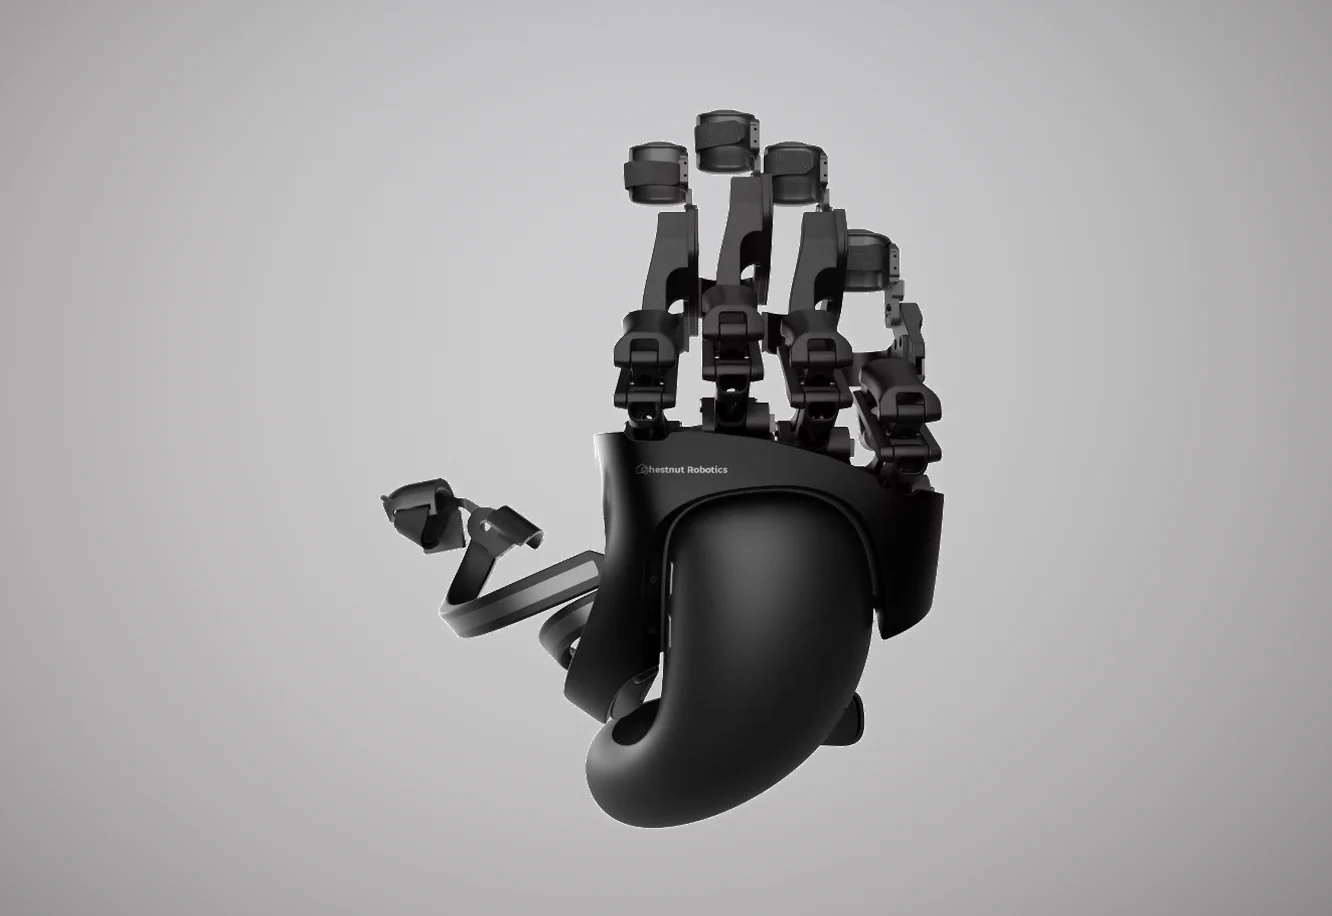
Aero Hand

Dexterity, engineered for repeated real-world use

An 18-DoF, human-hand-sized robotic hand with direct drive and tactile sensing, built for precise, reliable contact with small, fragile or tightly fitted parts.

SpecificationAero Hand
Degrees of freedom18 (15 active + 3 passive)
Form factorHuman-hand-sized
DrivetrainDirect drive
Lifetime (MTBF)> 300,000 full grasps
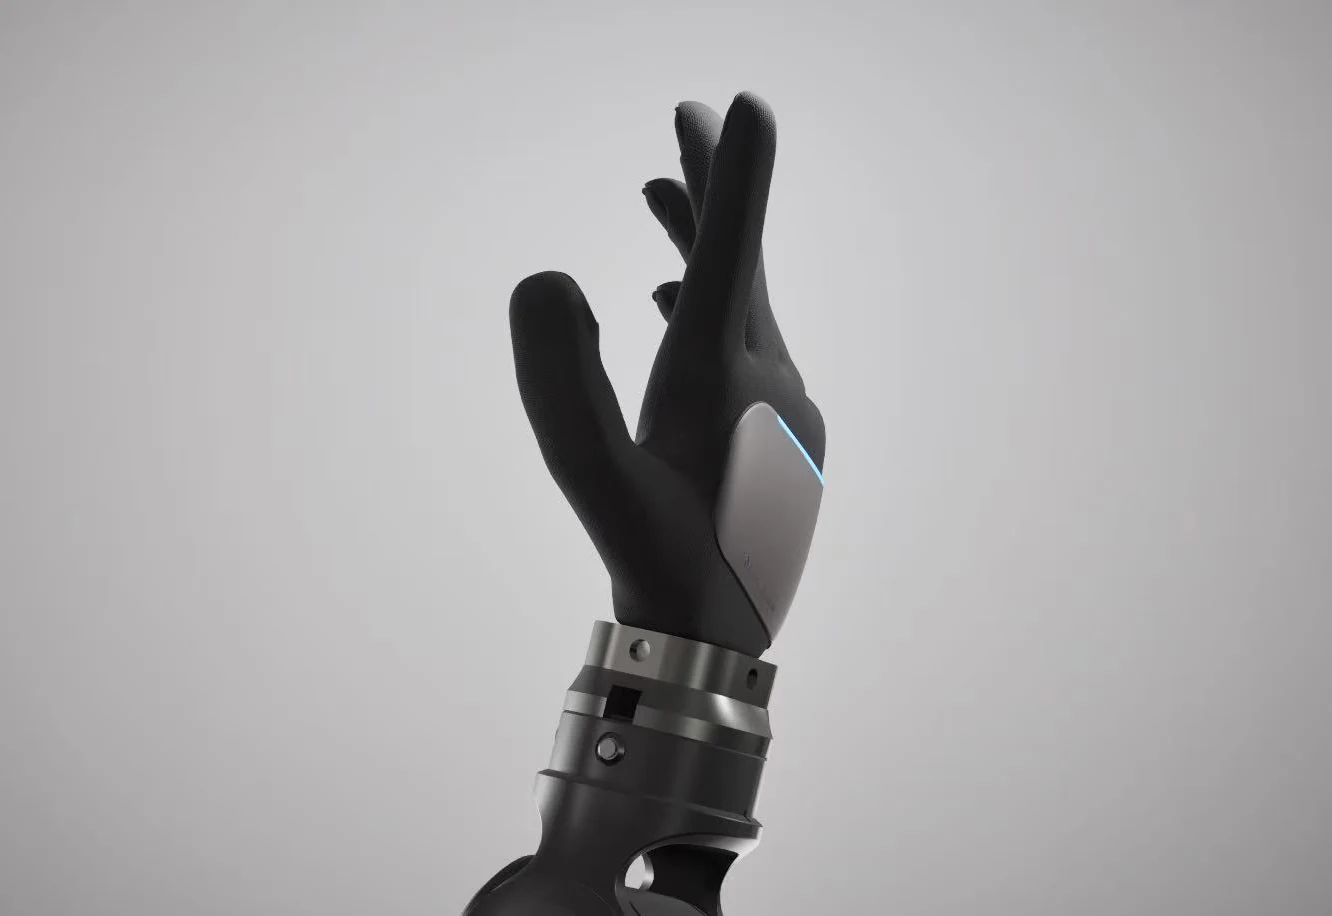
Aero UMI

Aero UMI

Human demonstrations, measured directly

A wearable interface for collecting demonstrations and teleoperating robots. Magnetic encoders measure each joint directly, and its URDF matches Aero Hand joint for joint.

SpecificationAero UMI
Primary functionsDemonstration collection and teleoperation
Joint sensingDirect measurement with magnetic encoders
Joint repeatability0.1°
Encoder precision0.05°
Kinematic modelURDF matched to Aero Hand

Can Aero UMI be used independently?

Yes. Aero UMI can collect demonstrations independently of Aero Hand. Using those demonstrations with a different robotic hand requires retargeting: mapping the recorded motion to that hand’s structure, joint limits and available movements.

Talk to us about your configuration
Why Aero?

Dexterity has to be learned. The hardware has to make that learning useful.

Real manipulation varies with every object, position and contact. Learning-based control needs demonstrations that capture those details, and hardware that can reproduce them reliably.

  1. 01 / Data

    Capture motion and contact

    Video shows what an action looks like, but not every joint angle or contact force. Aero UMI measures joint motion directly, and shared tactile sensing links how a task is demonstrated with how it is executed.

  2. 02 / Matched design

    Design the interface and the hand together

    A demonstration is tied to the body that made it. Aero UMI and Aero Hand share matched kinematics, so demonstrations transfer with less mismatch. It doesn’t replace robot learning; it gives it a more consistent foundation.

  3. 03 / Practical collection

    Build around the person doing the work

    Aero UMI is light and comfortable enough to wear again and again, and it captures movement directly while the operator works, with nothing to reconstruct afterwards.

  4. 04 / Reliable execution

    Treat durability as part of the system

    A learned skill only matters if the hand can repeat it. Aero Hand’s direct drive and MTBF of more than 300,000 full grasps are built for repeated real-world use.

One interface for demonstration and teleoperation

The same Aero UMI records tasks and guides the hand remotely, so an operator can step in when the robot meets something new.

Connecting human video with measured demonstrations

Ordinary video offers broad examples but no joint or force data. Aero Hand’s human-like structure can learn from video, while Aero UMI adds precise, measured demonstrations.

Bring us your application

Whether you’re a research lab, a university or a company, we’d like to work with you. Tell us what you’re building, and we’ll find the right way to collaborate.

Our first Aero System production batch is expected to be ready in late October 2026. Contact us to discuss your preferred configuration, availability, delivery timing and pricing.