← Aero System
Aero Hand
18-DoF five-finger biomimetic dexterous hand
Built for humanoid robots, research and specialized work. Highly biomimetic five fingers, built-in 3D tactile sensing, direct drive and a lightweight design.
Full specifications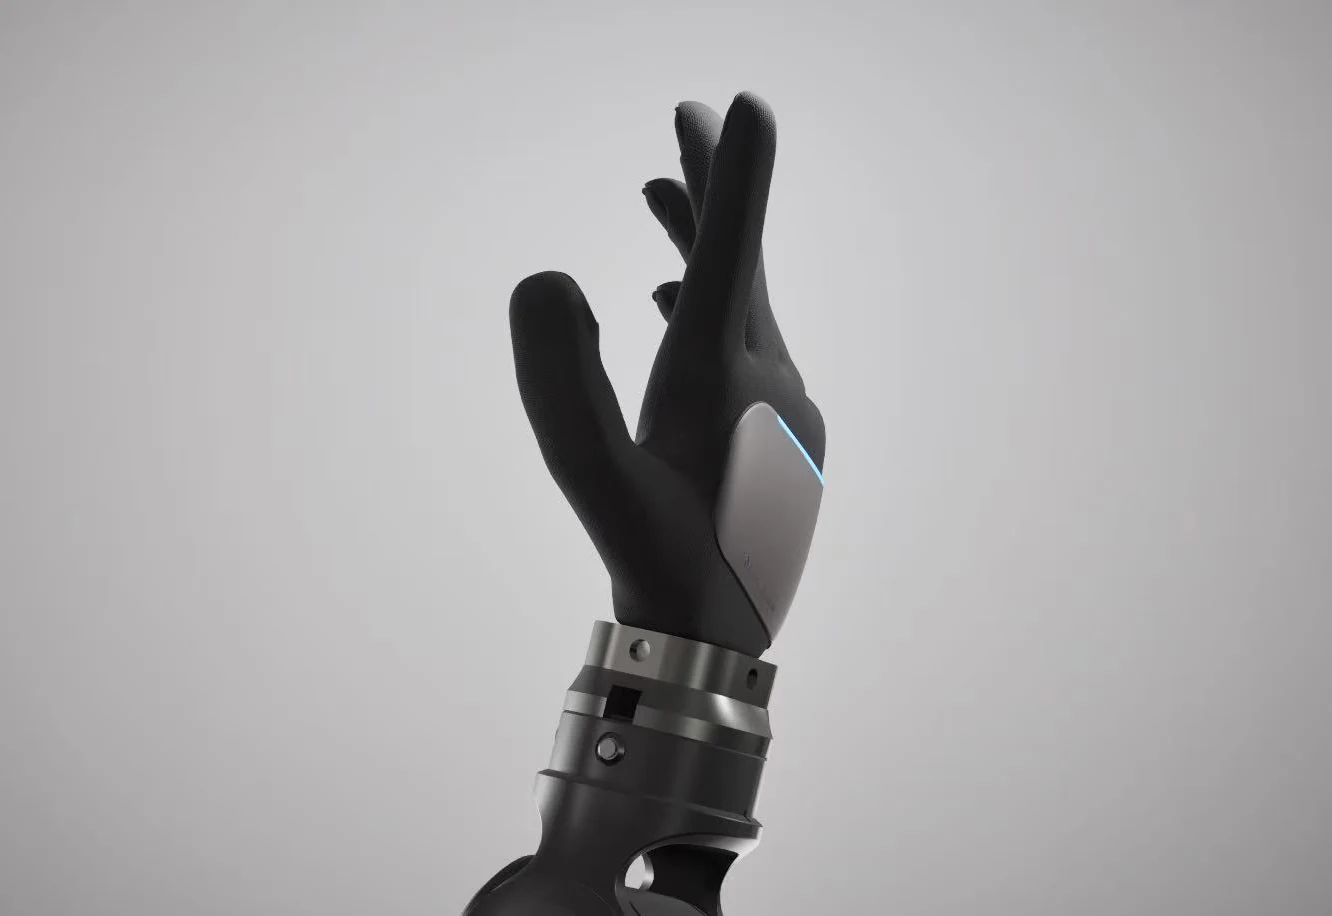
18 DoF15 active + 3 passive
10 NFingertip force
≤ 0.5 sFull open to full close
±1.0 mmRepeatability
≤ 800 gWeight
IP54Dust and splash resistant
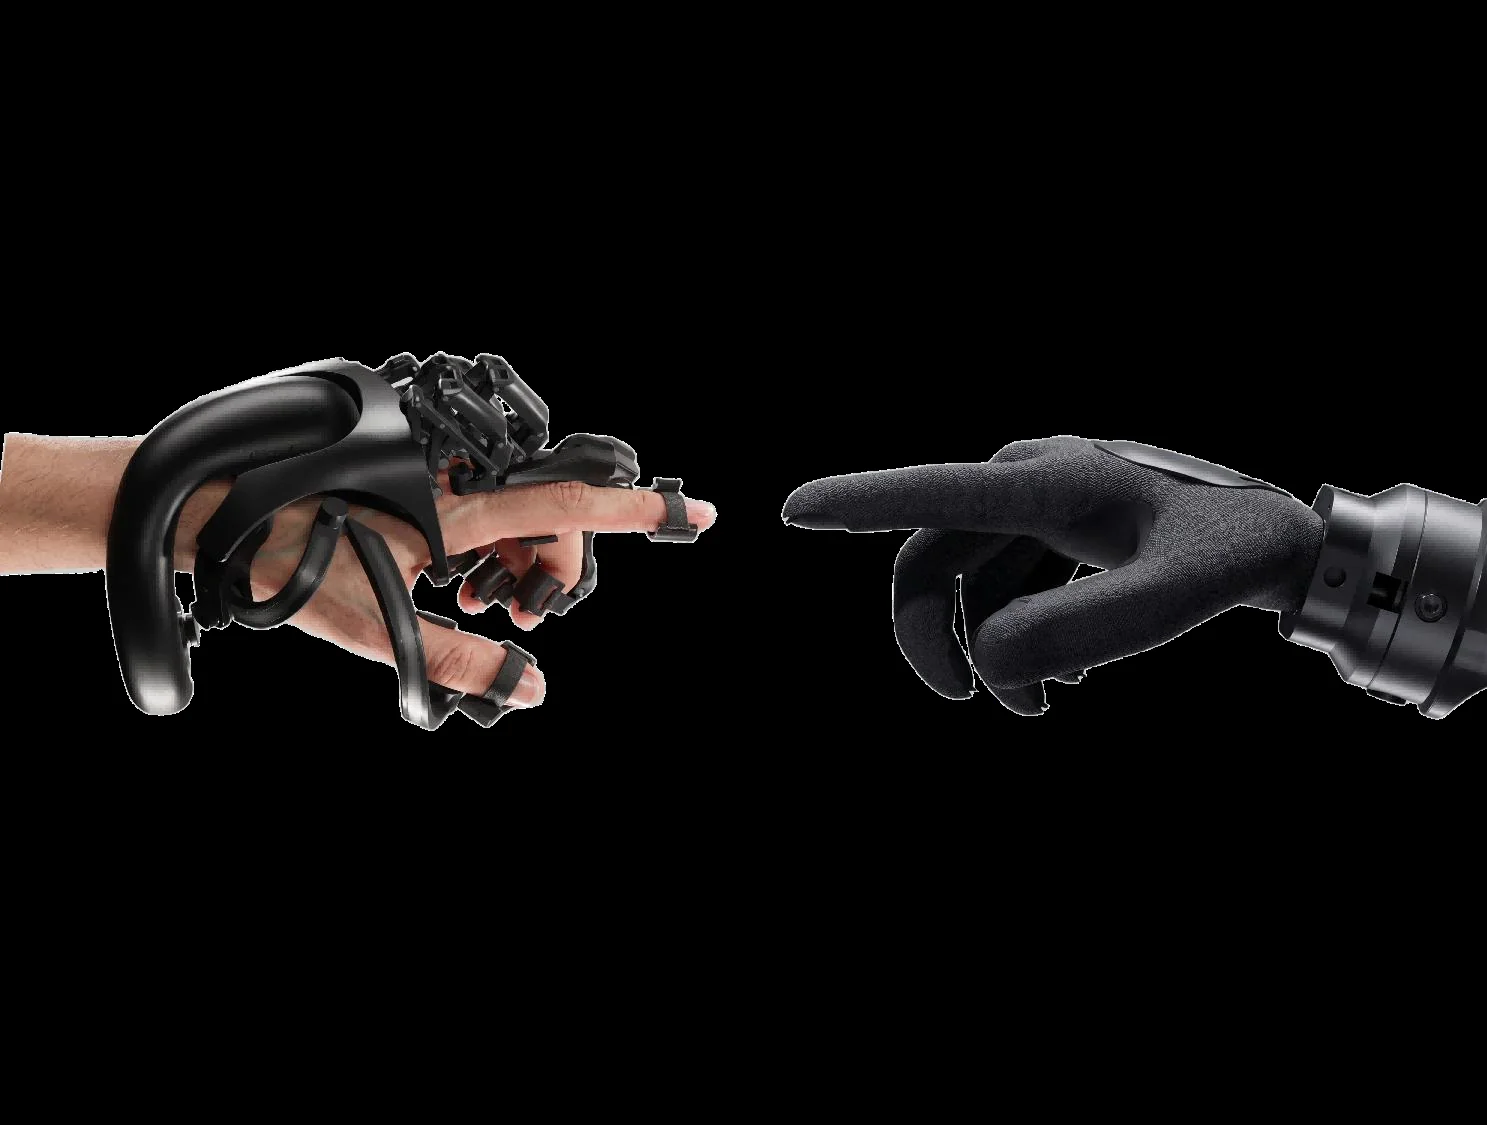
Pairs with Aero UMI
Matched joint for joint
Aero Hand is 100% matched to Aero UMI, joint for joint. Human demonstrations captured with Aero UMI are carried out by Aero Hand.
18Matched degrees of freedom
0.05°Encoder precision
0.1 NTactile resolution
Specifications
Aero Hand
18-DoF five-finger biomimetic dexterous hand for humanoid robots, research and specialized work.
01 Structure and performance
| Specification | Aero Hand |
|---|---|
| Kinematic structure | 18 DoF (15 active + 3 passive) |
| DoF distribution | Thumb 3 (opposable) · index, middle and ring 3 + 1 passive each · little finger 3 |
| Drive | Direct drive |
| Fingertip force | 10 N |
| Closing speed | Full open to full close ≤ 0.5 s |
| Repeatability | ±1.0 mm |
| Weight | ≤ 800 g |
| Dimensions | 198 × 103 × 43 mm |
| Protection and impact | IP54 (dust and splash resistant) · passes 1 m drop test |
| Lifetime (MTBF) | > 300,000 full grasps |
02 Sensing and control
| Specification | Aero Hand |
|---|---|
| Joint angle sensing | 14-bit high-precision magnetic encoders, 0.05° precision |
| Joint torque | Estimated from motor current |
| Tactile sensing | Fingertips and palm, high-resolution multi-dimensional flexible arrays |
| Tactile resolution | 0.1 N |
| Control modes | Position · velocity · torque/current (MIT mode) · impedance |
| Control frequency | 10 kHz low-level current loop |
| Communication | CAN FD (EtherCAT in a future version) |
| Operating voltage | 20–50 VDC wide input |
| Supported systems | Ubuntu · Windows · ROS 2 |
| SDK / API | C++ / Python libraries · URDF · teleoperation support |
Bring us your application
Tell us about your task, hardware and data requirements, and we’ll help you find the right configuration.