Where robot dexterity begins
ScrollBring capable, reliable robots into everyday life.
We believe more people should benefit from robots that can do useful work in businesses, communities and homes.
Getting there requires robots that can handle the physical world with greater skill and reliability. Chestnut builds dexterous hands and the systems that help robots learn to use them, giving researchers and robot builders a foundation for bringing more capable robots to more people.
Built to learn. Built to last. Designed together.
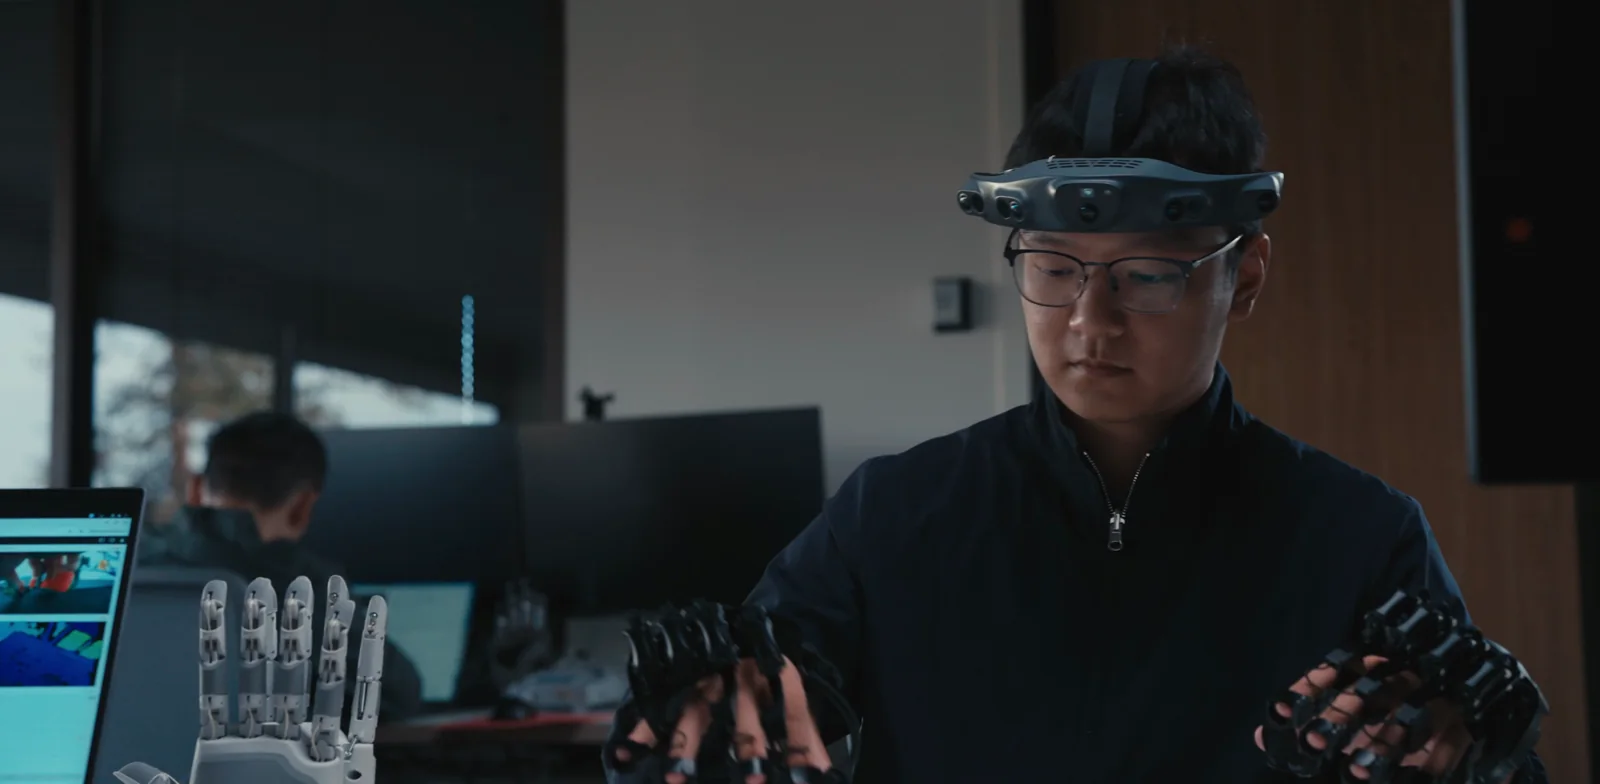
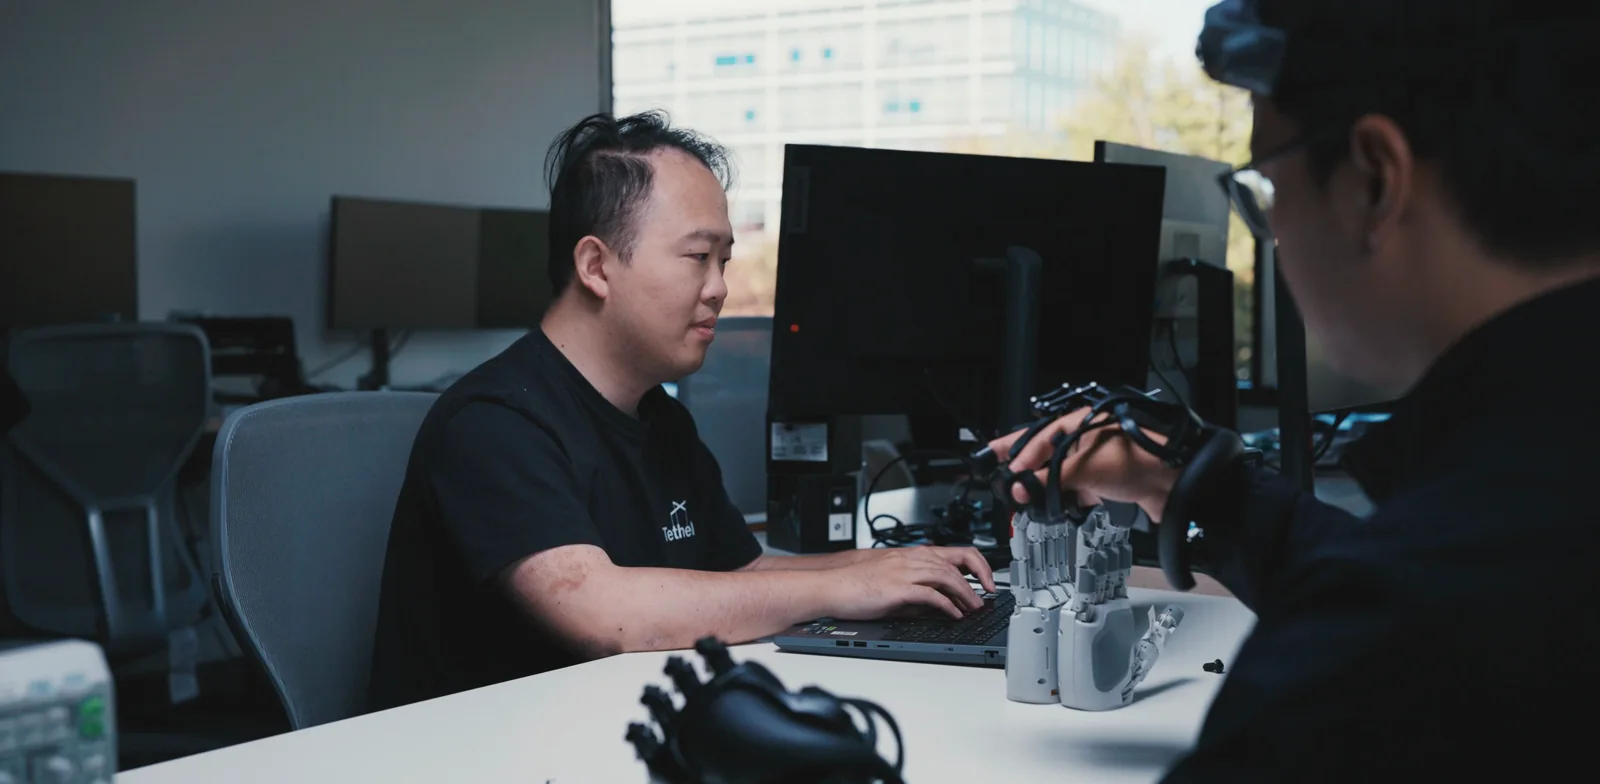
Dexterous robotics needs two things to advance: durable hands that can perform repeatedly, and demonstrations that robots can learn from.
We co-design Aero UMI, Aero Hand and supporting software to connect human demonstrations with robotic execution. Aligning motion and contact across the system helps preserve the details that matter for precise manipulation.
Our goal is to make dexterous skills easier to teach, more reliable to execute and practical to deploy at scale.
Hardware and intelligence, built together.
Chestnut brings together experience in precision hardware, AI and robotics. We work across mechanical design, sensing, software and learning because reliable manipulation depends on how the whole system works together.
Precision hardware. Built for scale.
Evan brings over a decade of hardware engineering experience across Tesla, Apple and ASML, including work on dexterous hands, Apple Vision Pro and semiconductor manufacturing systems. His expertise spans precision engineering, product development and manufacturing. Evan is bringing together the dexterity, durability and production discipline needed to make robotic hands practical for real-world use.
Robot intelligence. Grounded in the real world.
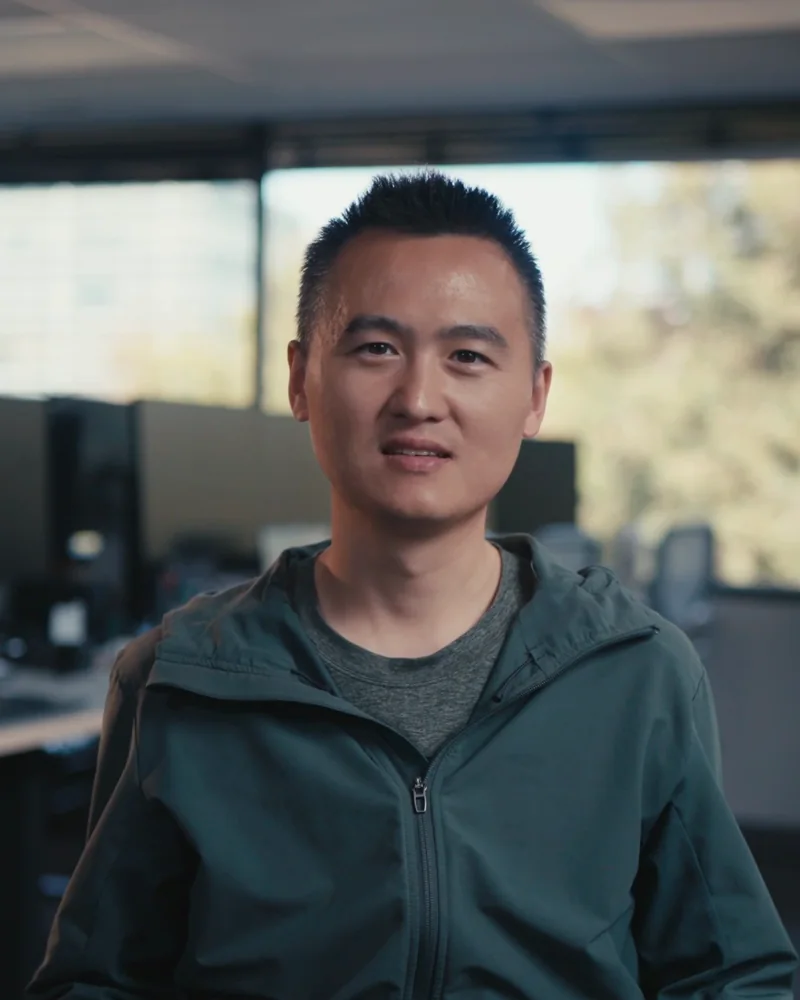
Joe brings over a decade of experience in AI, computer vision and autonomous systems, including technical leadership at Waymo and Xpeng. He has built perception and learning systems for autonomous driving, where reliability must extend across complex, unpredictable conditions. At Chestnut, he brings that experience to robot learning to connect human demonstrations with precise, reliable manipulation.
Build for the world people live in.
Start with useful work.
Let real tasks and the people who perform them guide what we build.
Design the whole system.
Develop hardware, data and software together, with learning and execution in mind from the start.
Make reliability a requirement.
Treat durability, repeatability and maintenance as core design decisions.
Help others build.
Create tools that researchers, educators and robot builders can use to advance their own work.
Help shape what robots can do next.
We’re bringing together engineers, researchers and partners to advance dexterous robotics and make its benefits available to more people.