Aero UMI
Five-finger dexterous manipulation data-collection system
A wearable manipulation interface for collecting demonstrations and teleoperating robots. Matched joint for joint to Aero Hand, it records how a person moves and how hard they press, with every signal on one clock.
Full specifications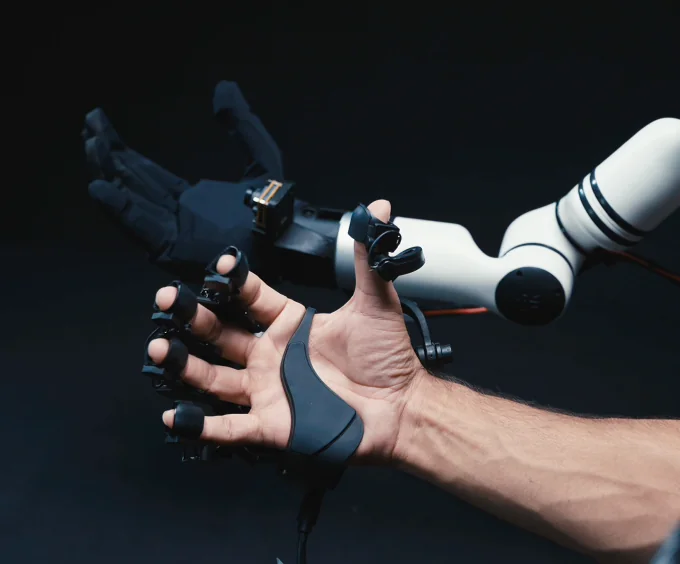
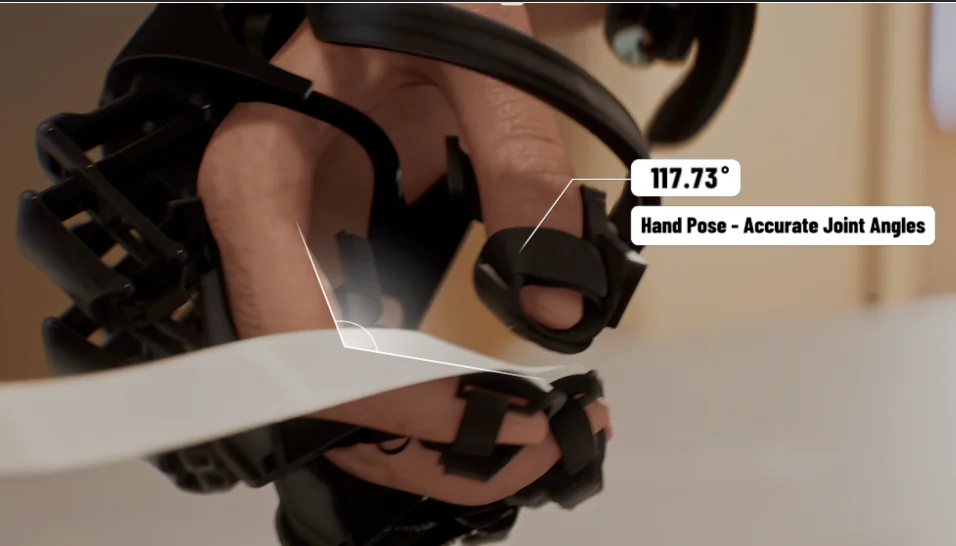
Joint by joint
Designed to match Aero Hand. Magnetic encoders read each joint angle directly, and calibration maps it to the corresponding joint on the hand.
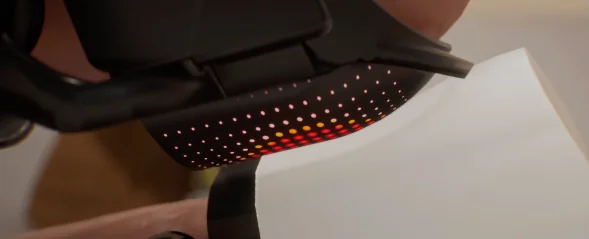
Record how force changes
Captures the detail of contact force at the fingertips and palm as a task unfolds.
Every signal shares one moment.
All data streams run on one hardware-triggered clock, aligned to within 1 ms. Alignment is verified on every recording, not spot-checked.
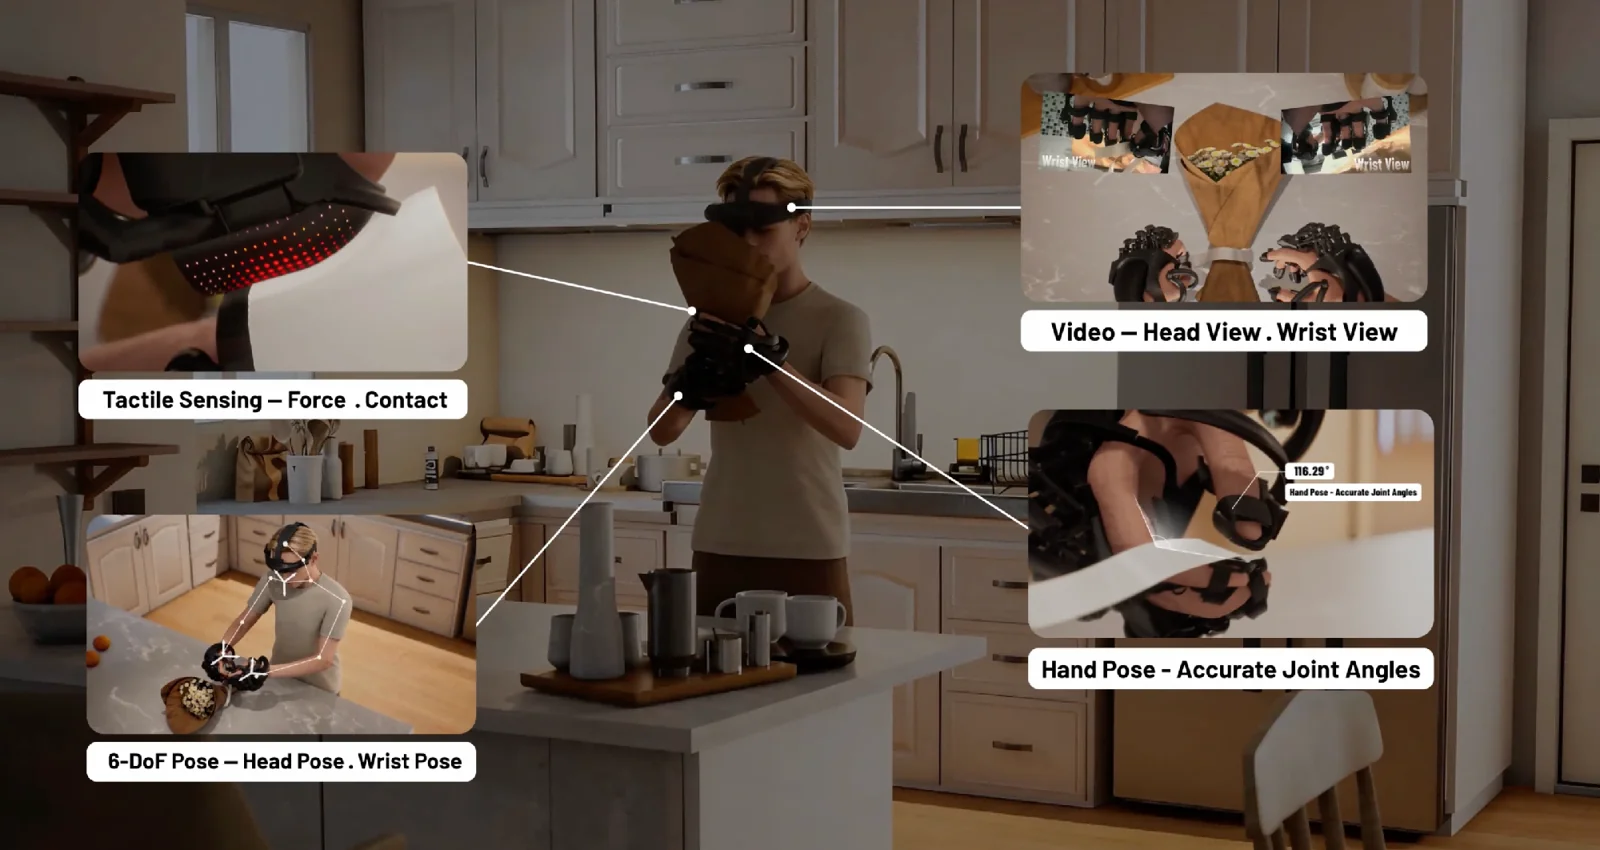
- Hand joint angles
- Fingertip force
- Wrist 6-DoF pose
- Head 6-DoF pose
- Egocentric stereo RGB
- Wrist camera (configurable)
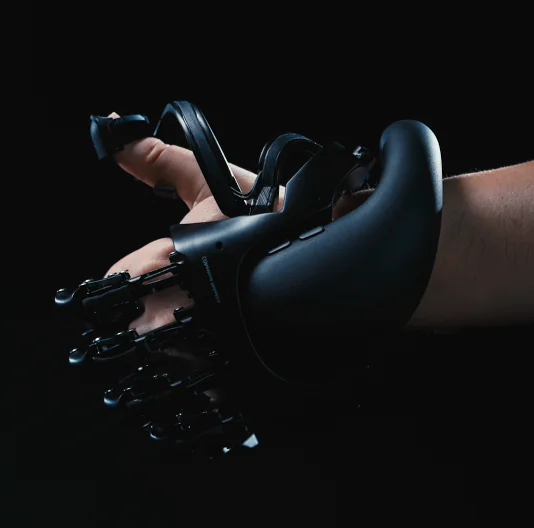
Light to wear. Quick to start.
Designed for high-precision collection that can run all day, so data collection fits the person doing the task.
The same interface drives the hand.
Aero UMI also works as a teleoperation rig: the operator moves, and Aero Hand follows in real time.
Data-collection kit
Head module plus the Aero UMI exoskeleton, for capturing human demonstrations of five-finger dexterous manipulation.
01 Head module
| Specification | Head module |
|---|---|
| Main cameras | Global-shutter stereo RGB ×5 |
| Depth sensing | ToF ×1, 640 × 480 |
| Illumination | Active infrared |
| Field of view | 208° horizontal · 193° vertical |
| Head pose | 6-DoF (VIO + IMU) |
| Optical 6-DoF reference | Sub-millimeter trajectory accuracy |
| Time sync | < 1 ms |
| Hand tracking (bare hand) | 21 keypoints, MPJPE ≤ 10 mm |
| Weight | 240 g |
| Continuous capture | 8 h |
02 Aero UMI exoskeleton
| Specification | Aero UMI |
|---|---|
| Kinematic structure | 18 joints, matched to Aero Hand |
| Hand tracking (wearing UMI) | Joint angles read directly from encoders, 0.05° precision |
| Repeatability | 0.1° / sub-millimeter |
| Wrist 6-DoF | Optical-inertial fusion |
| Force sensing | 0.1 N resolution |
| Force channels | 54–57 per fingertip, 213 on the palm |
| Hand size fit | 50th-percentile adult male |
| Weight | 320 g |
| Time to put on | < 10 s |
| Continuous capture | 8 h (with spare battery) |
Every data stream shares one hardware-triggered clock: hand joint angles, fingertip force, wrist 6-DoF, head 6-DoF and egocentric stereo RGB, aligned to within 1 ms and verified on every recording rather than spot-checked.
Bring us your application
Tell us about your task, hardware and data requirements, and we’ll help you find the right configuration.